Loading...
Searching...
No Matches
RuleConfig Struct Reference
A configuration structure used to instantiate any type of RuleStrategy. More...
#include <Strategy.hpp>
Collaboration diagram for RuleConfig:
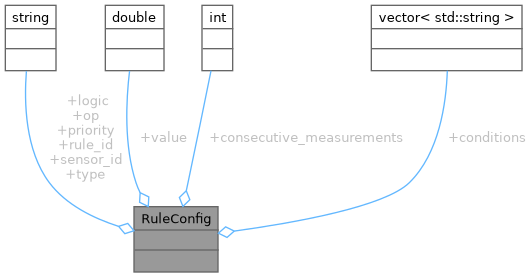
Public Attributes | |
| std::string | type |
| The type of the rule (e.g., "simple", "stateful", "correlation"). | |
| std::string | sensor_id |
| The ID of the sensor this rule applies to. | |
| std::string | rule_id |
| The unique identifier for the rule. | |
| std::string | priority = "LOW" |
| The execution priority level (default: "LOW"). | |
| double | value = 0.0 |
| The numerical threshold value used for comparisons. | |
| int | consecutive_measurements = 1 |
| The required consecutive steps for stateful rules to trigger. | |
| std::vector< std::string > | conditions |
| A list of dependent rule IDs for correlation rules. | |
| std::string | op =">" |
| The comparison operator used for standard rules (default: ">"). | |
| std::string | logic = "AND" |
| The logical operator used for correlation rules (default: "AND"). | |
Detailed Description
A configuration structure used to instantiate any type of RuleStrategy.
Member Data Documentation
◆ conditions
| std::vector<std::string> RuleConfig::conditions |
A list of dependent rule IDs for correlation rules.
◆ consecutive_measurements
| int RuleConfig::consecutive_measurements = 1 |
The required consecutive steps for stateful rules to trigger.
◆ logic
| std::string RuleConfig::logic = "AND" |
The logical operator used for correlation rules (default: "AND").
◆ op
| std::string RuleConfig::op =">" |
The comparison operator used for standard rules (default: ">").
◆ priority
| std::string RuleConfig::priority = "LOW" |
The execution priority level (default: "LOW").
◆ rule_id
| std::string RuleConfig::rule_id |
The unique identifier for the rule.
◆ sensor_id
| std::string RuleConfig::sensor_id |
The ID of the sensor this rule applies to.
◆ type
| std::string RuleConfig::type |
The type of the rule (e.g., "simple", "stateful", "correlation").
◆ value
| double RuleConfig::value = 0.0 |
The numerical threshold value used for comparisons.
The documentation for this struct was generated from the following file:
- include/RulesFactory/Strategy.hpp