Loading...
Searching...
No Matches
EvaluationPipeline Struct Reference
Holds the categorized and organized rules ready for execution. More...
#include <RuleOrdering.hpp>
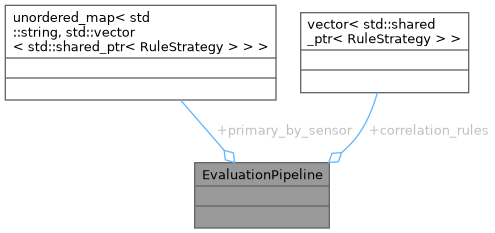
Collaboration diagram for EvaluationPipeline:
Public Attributes | |
| std::unordered_map< std::string, std::vector< std::shared_ptr< RuleStrategy > > > | primary_by_sensor |
| Map of primary rules grouped by their target sensor ID. | |
| std::vector< std::shared_ptr< RuleStrategy > > | correlation_rules |
| Collection of correlation rules. | |
Detailed Description
Holds the categorized and organized rules ready for execution.
Member Data Documentation
◆ correlation_rules
| std::vector<std::shared_ptr<RuleStrategy> > EvaluationPipeline::correlation_rules |
Collection of correlation rules.
These depend on primary rules and must be evaluated after all primary rules have completed.
◆ primary_by_sensor
| std::unordered_map<std::string, std::vector<std::shared_ptr<RuleStrategy> > > EvaluationPipeline::primary_by_sensor |
Map of primary rules grouped by their target sensor ID.
Stored in an unordered_map to facilitate parallel evaluation across different sensors.
The documentation for this struct was generated from the following file:
- include/RulesFactory/RuleOrdering.hpp