Loading...
Searching...
No Matches
Evaluate Class Reference
Responsible for applying rule strategies to data points and generating evaluation results. More...
#include <Evaluate.hpp>
Collaboration diagram for Evaluate:
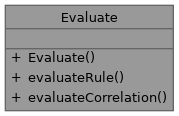
Public Member Functions | |
| Evaluate ()=default | |
| Default constructor. | |
| EvaluationResult | evaluateRule (const DataPoint ¤t_data, const std::shared_ptr< RuleStrategy > &rule) |
| Evaluates primary rules (Simple, Step, Stateful) against a specific data point. | |
| EvaluationResult | evaluateCorrelation (const std::shared_ptr< RuleStrategy > &rule, const ResultMap ¤t_timestamp_results, const std::vector< DataPoint > &ts_data, const std::unordered_map< std::string, std::vector< std::string > > &rule_to_sensors) |
| Evaluates correlation rules by analyzing the outcomes of all evaluated rules for the current timestamp. | |
Detailed Description
Responsible for applying rule strategies to data points and generating evaluation results.
Constructor & Destructor Documentation
◆ Evaluate()
|
default |
Default constructor.
Member Function Documentation
◆ evaluateCorrelation()
| EvaluationResult Evaluate::evaluateCorrelation | ( | const std::shared_ptr< RuleStrategy > & | rule, |
| const ResultMap & | current_timestamp_results, | ||
| const std::vector< DataPoint > & | ts_data, | ||
| const std::unordered_map< std::string, std::vector< std::string > > & | rule_to_sensors | ||
| ) |
Evaluates correlation rules by analyzing the outcomes of all evaluated rules for the current timestamp.
- Parameters
-
rule A shared pointer to the correlation rule strategy. current_timestamp_results The map containing the true/false outcomes of all evaluated rules for this timestamp. ts_data The data points for the current timestamp. rule_to_sensors Map from rule ID to its leaf sensor IDs. Primary rules map to a single sensor; correlation rules map to the union of their conditions' leaf sensors (built incrementally as they fire).
- Returns
- An EvaluationResult containing the nominal status and any relevant correlation alarm message.
◆ evaluateRule()
| EvaluationResult Evaluate::evaluateRule | ( | const DataPoint & | current_data, |
| const std::shared_ptr< RuleStrategy > & | rule | ||
| ) |
Evaluates primary rules (Simple, Step, Stateful) against a specific data point.
- Parameters
-
current_data The data point to be evaluated. rule A shared pointer to the primary rule strategy to apply.
- Returns
- An EvaluationResult containing the nominal status and any relevant alarm message.
The documentation for this class was generated from the following files:
- include/Engine/Evaluate.hpp
- src/Engine/Evaluate.cpp