Loading...
Searching...
No Matches
Rules.hpp File Reference
Contains the implementation of the different rules. More...
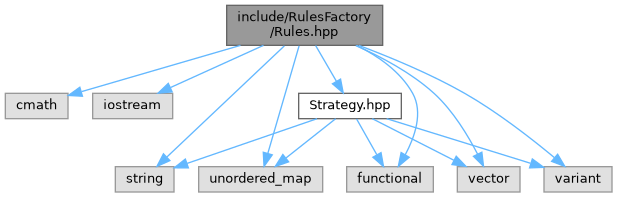
#include <cmath>#include <iostream>#include <string>#include <unordered_map>#include <functional>#include <vector>#include <variant>#include "Strategy.hpp"
Include dependency graph for Rules.hpp:
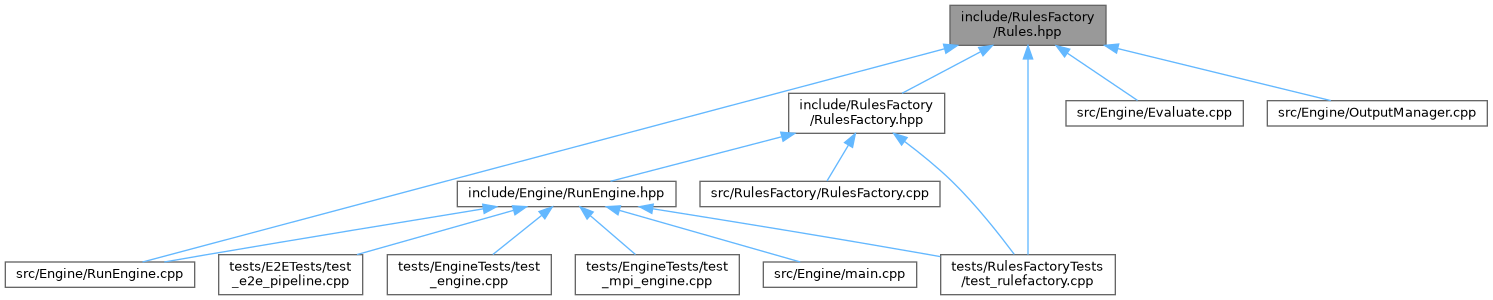
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| class | SimpleRule |
| A straightforward rule that compares a single sensor measurement against a threshold. More... | |
| class | StatefulRule |
| A rule that requires a condition to be met for a specified number of consecutive measurements. More... | |
| class | CorrelationRule |
| A rule that evaluates a combination of other rules based on logical operators (AND/OR). More... | |
| class | StepDifferenceRule |
| A rule that triggers based on the difference between the current and the previous measurement. More... | |
Detailed Description
Contains the implementation of the different rules.
Each rule inherits from RuleStrategy and implements the evaluate method according to its specific logic.